Silicon for motion,
power and sensing.
DeepGrid is developing silicon for motion, power, sensing and communications. Explore the product architectures, their role in your equipment, and the evidence needed before adoption.
Architecture and engineering evidence today. Manufactured-silicon results and qualification still ahead.
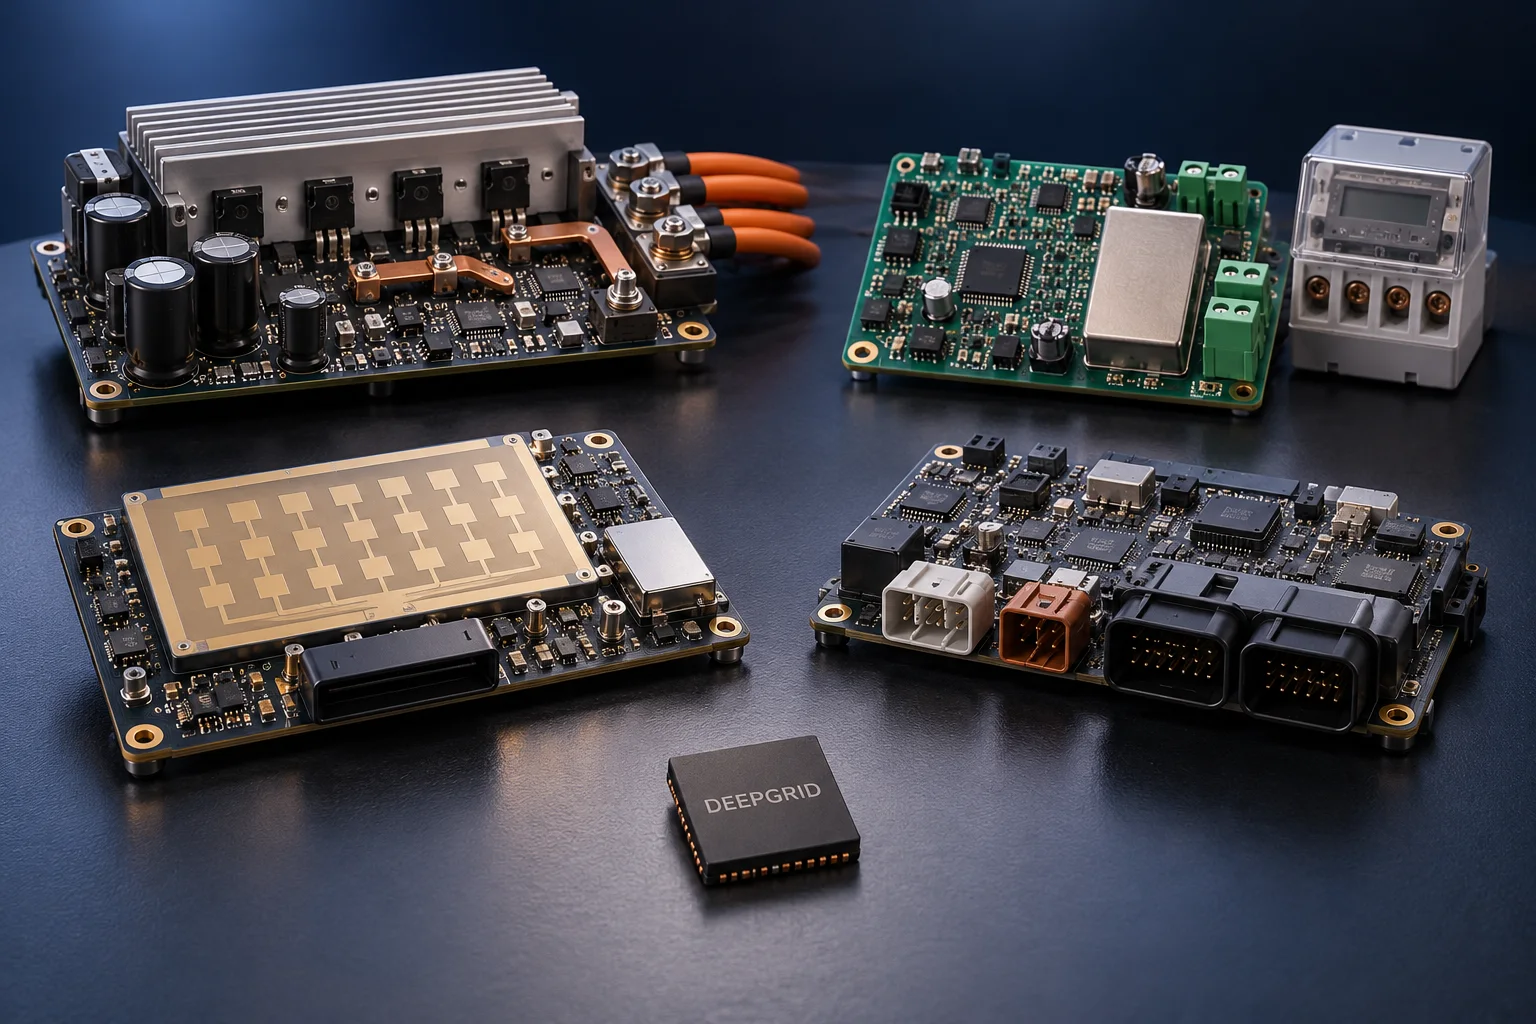
Twelve architectures.
Two carry engineering evidence today.
Compare the customer problem each product addresses, its role in the equipment and its current evidence. Product breadth does not imply equal readiness.
12 architectures · Pre-silicon portfolio
- 12architecturesPre-silicon portfolio · SKU Blueprint
- 39 cyclesinjected fault to protective responseSimulated · DG32-LITE Architecture Guide
- 55 to 62 MHzlockstep core, sets the 50 MHz clockPost-route · DeepGrid Datasheets Engineering Specification
- 130 nmprocess, for 28 to 120 V railsProcess nominal · Mature-Node Silicon System Architecture
Hardware fault response in 39 cycles.
In simulation, DG32 detects a processor disagreement and trigger a protective response without waiting for application software. The important decision is whether that response meets the needs of the complete machine.
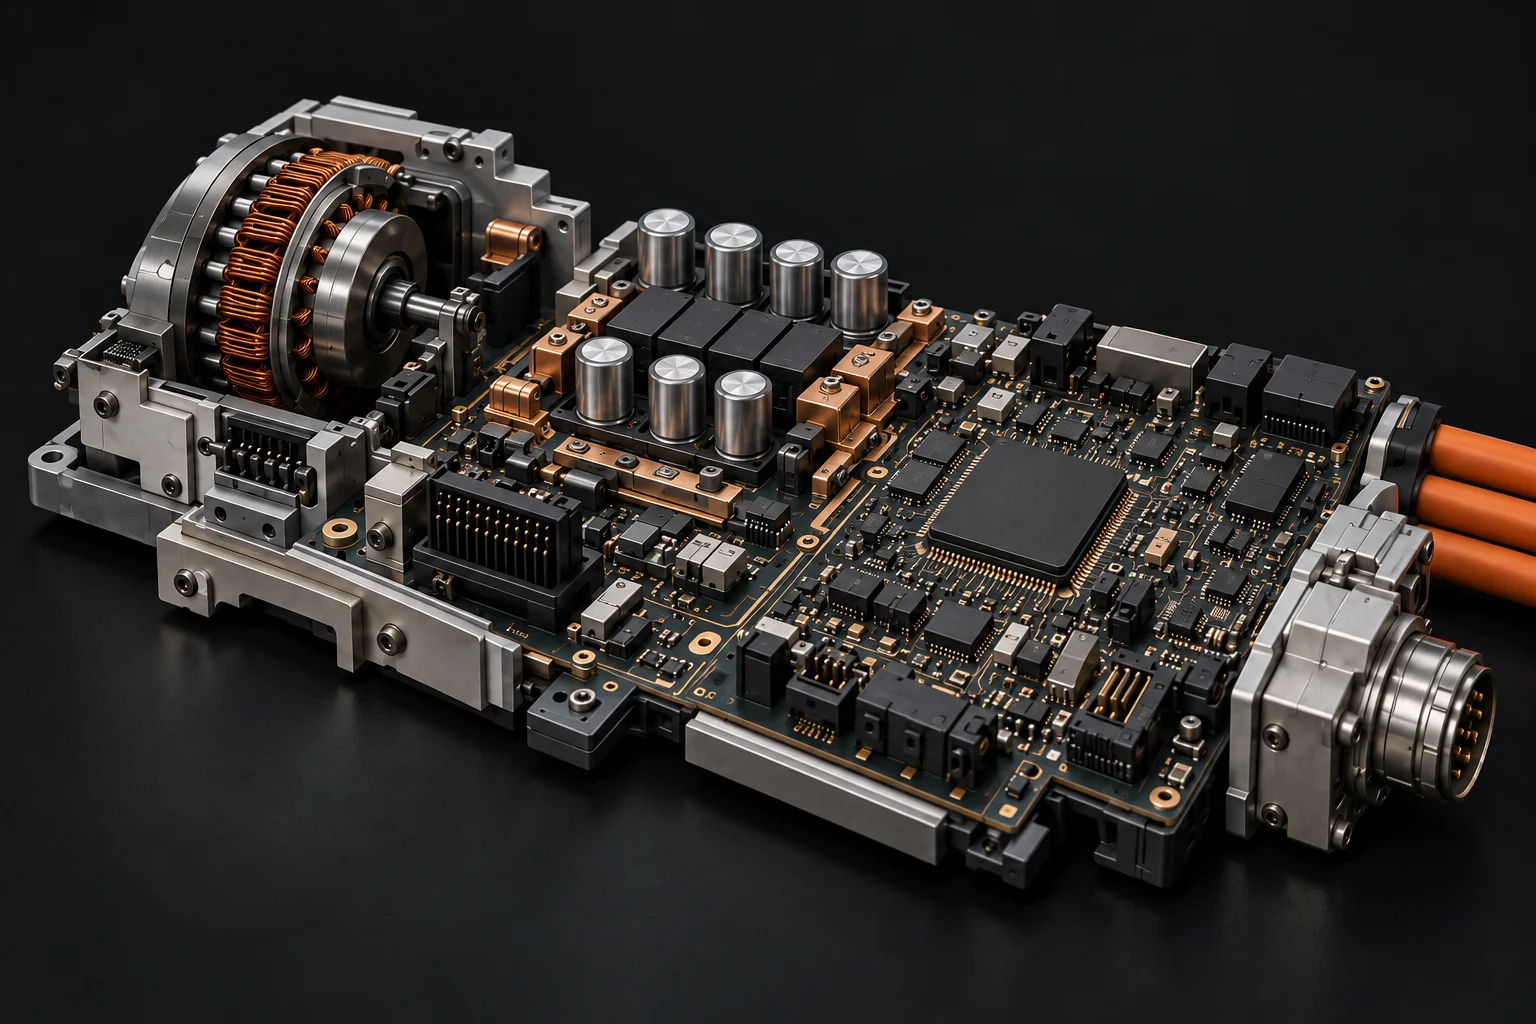
Illustrative lid separation; not a physical die layout.
- 01MAIN executesResults agree
- 02CHECKER follows · 2-cycle skewResults agree
- 03Comparator detects mismatchWaiting for mismatch
- 04Sticky fault latch records causeWaiting for mismatch
- 05FAULT_N asserts lowWaiting for mismatch
- 06Gate-driver disabledWaiting for mismatch
Normal operation: MAIN and the delayed CHECKER results agree. Inject a mismatch to follow the response.
Interactive explanation, not an executable silicon simulation. The animation is slowed for reading; reported fault latency: 39 cycles · simulated. The complete causal path remains readable without WebGL or motion.The complete reported path differs from the checker’s two-cycle execution skew. Hardware lockstep is a mechanism, not a functional-safety certificate.
Read the fault-path sourceControl, power and interfaces
in one system.
A product earns its place by solving a system problem. Explore how control, power and interfaces contribute to the equipment, and which responsibilities remain outside the chip.
Explore system applications
Original DeepGrid architecture diagram · pre-silicon design. Explore this part
A representative assembly. Select a function to locate its sockets.
Product labels identify roles, not a validated reference board. Sensing is a conceptual socket, not an assigned component in this illustration.DG32 physical design.
Silicon validation comes next.
The DeepGrid Silicon Engine capture shows the DG32-LITE layout. It records pre-silicon design work; manufactured-silicon measurements and product qualification are separate milestones.
Inspect the complete layout image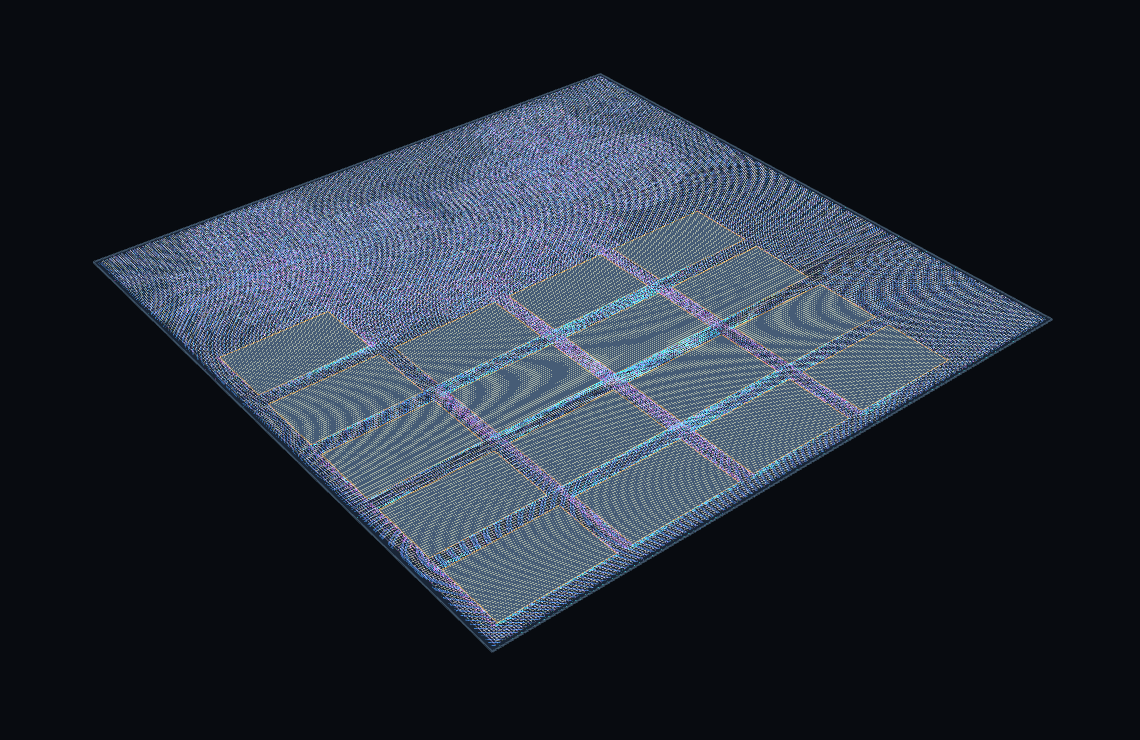
Pre-silicon validation.
Qualification still ahead.
Architecture breadth, engineering work and commercial readiness answer different questions. Evaluate each on its own evidence.
Review evidence & withheld claimsCurrent engineering and commercial basis
- Portfolio architectures and dated SKU Blueprint tables
- DG32 simulation, implementation and post-route records
- Named approval routes and estimated unit costs
Silicon, qualification and customer milestones
- Returned-silicon measurements and confirmed sample dates
- Qualification and application-specific validation
- Purchase orders, letters of intent and reconciled financial assumptions
₹10 Cr funds first silicon for nine chips
on the December 2026 shuttle.
The Blueprint allocates ₹10 Cr in tranche 1 to first-silicon work. Its December shuttle plan includes 9 designs. This is a prototype milestone, with qualification and full development still ahead.
Review the funding briefSKU Blueprint, October 2026 · planned allocations, not capital received or silicon results.
Tranche 1 capital allocation
- Nine prototypes, December 2026 shuttle
- ₹2.6 Cr
- Respin reserve
- ₹2.5 Cr
- Engineering team
- ₹2.5 Cr
- First approvals
- ₹1 Cr
- Design tools and lab
- ₹1 Cr
- Contingency
- ₹0.3 Cr
- Bring-up and evaluation boards
- ₹0.1 Cr
The September model and October Blueprint use different revenue scopes. Read their reconciliation before comparing headline totals.
Compare the two plansPortfolio discussions, partner evaluations
and data-room access start here.
Request a portfolio discussion, strategic-partner evaluation or data-room access. Tell us which assumptions and evidence you want to examine.